ABOUT
ROMO Series
Hollow-Shaft Rotary Piezoelectric Motors
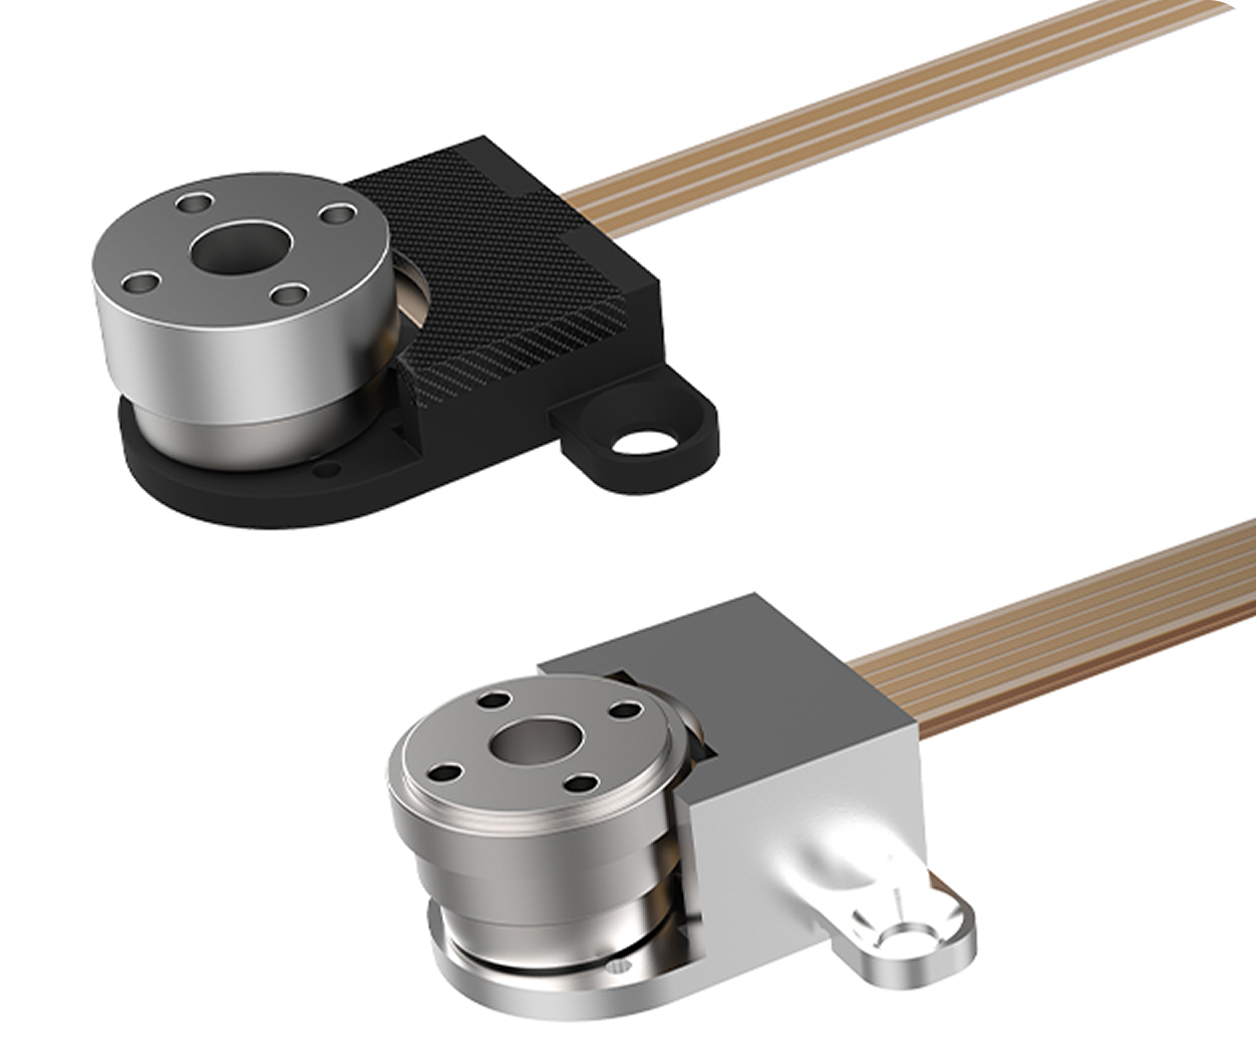
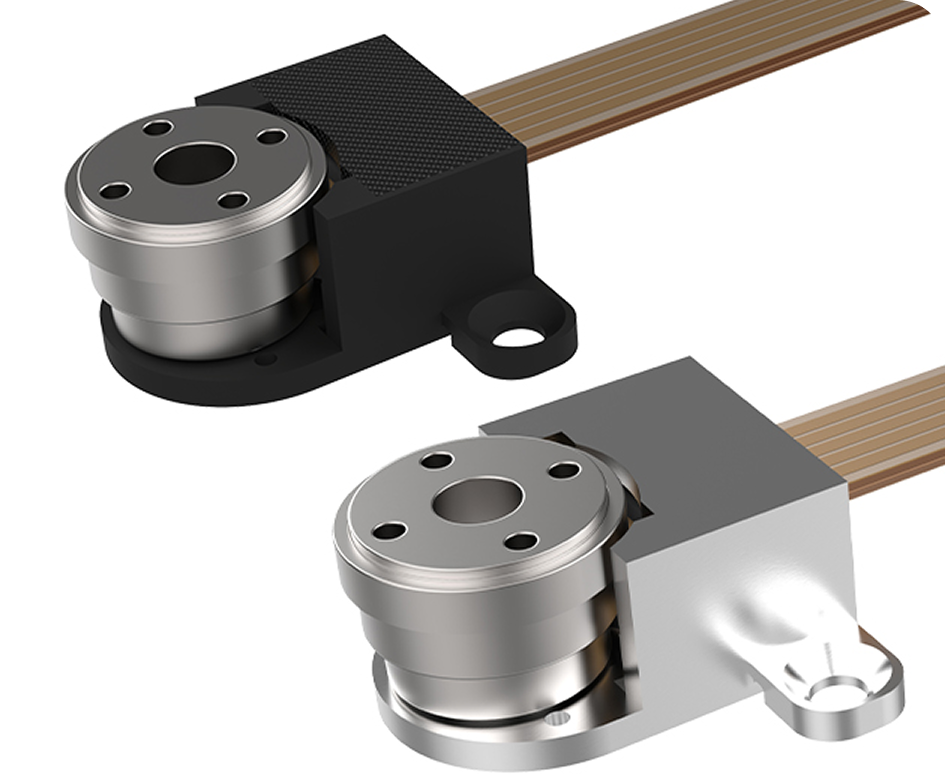
The ROMO Series is a hollow-shaft rotary piezo motor small enough to sit on a penny, built for space-constrained designs where every cubic millimeter counts. Running on ultrasonic standing-wave excitation of a piezoceramic resonator, ROMO delivers a 30 µrad minimum step with ≥4 mNm stall torque — no gearbox, no magnets, no coils. And because it draws zero current at rest, it generates no heat and doesn’t drain your battery just sitting idle between moves — while still responding in under 30 µs the instant you command it.
KEY FEATURES
Performance and
Key Advantages
Key Advantages
Hollow shaft
2.5 mm I.D. (~11.5 mm O.D.), for routing wires, fiber, or light straight through the rotor axis
Sub-30 µs response
starts and stops faster than a stepper motor can take its first step
Zero holding power
draws no current at rest, unlike a DC or stepper motor
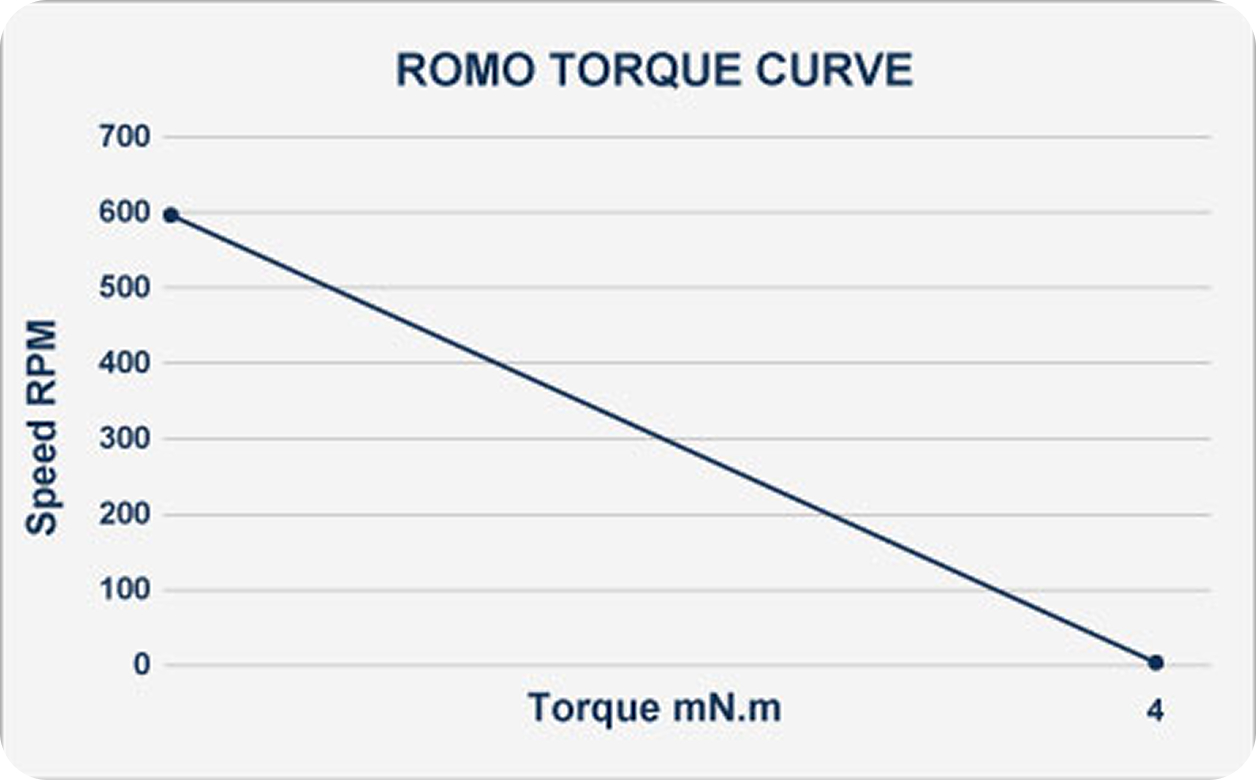
≥4 mNm stall torque
in a body as small as 3.5 g (plastic) to 5.2 g (metal, with encoder)
Resolution
30 µrad (open-loop)
6.1 mrad minimum step (closed-loop)
Power Supply
5–7.5 V DC, depending on driver configuration
HOW IT WORKS
Principle of Operation
US Patent Number 12,143,036
The ROMO rotary piezo actuator operates based on a US patented technology. Electrical excitation of its piezoceramic body, or resonator, induces simultaneously two independent longitudinal and bending ultrasonic standing waves in two perpendicular directions. This action generates elliptical vibrations at the resonator’s center, resulting in rotary motion of the motor, which is passively in contact with the resonator body.
SPECIFICATIONS
ROMO Series Motor Specifications
ROMO
Open Loop Rotary Piezo Motor
Open Loop Rotary Piezo Motor
Hollow Shaft Rotary | Plastic & Metal Enclosures | No Encoder
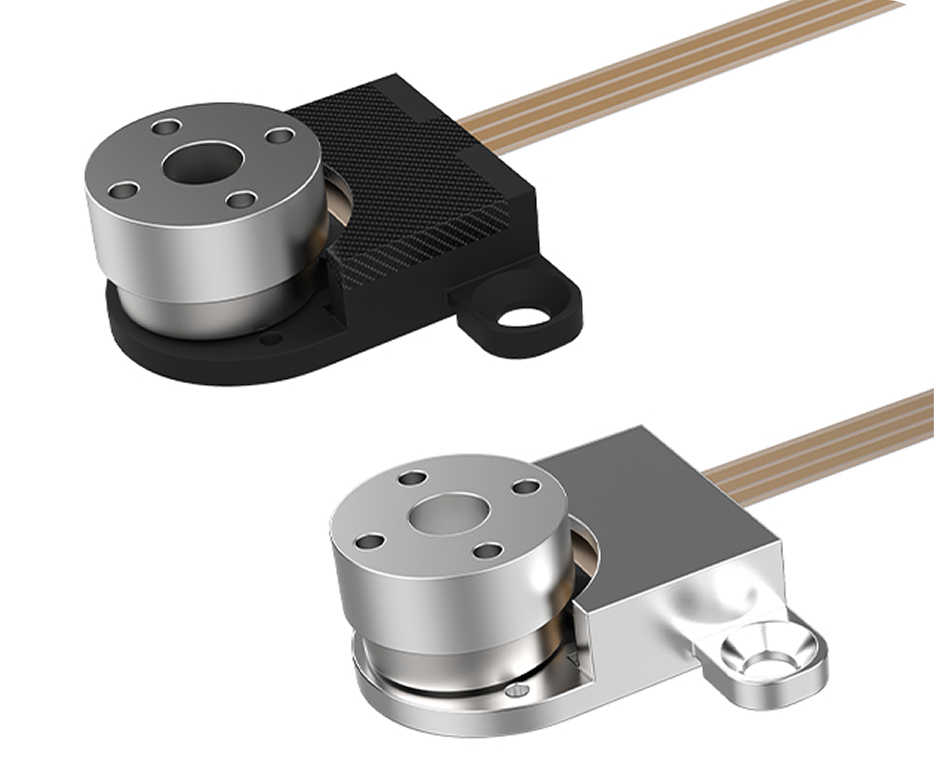
Hollow-shaft rotary piezoelectric actuator, open-loop PWM control. Available in plastic (ROMO-P) or machined anodized aluminum (ROMO-M) enclosure.
| MOTOR SPECIFICATIONS | |
| Power Supply Voltage | 7.5 V DC |
| Stall Torque | ≥ 4 mNm |
| Self-Braking Torque | ≥ 5 mNm |
| Actuator Response Time | < 30 µs |
| Max Speed | > 600 rpm |
| Minimum Angular Step | 30 µrad |
| Angular Backlash | 30 µrad |
| Angular Hysteresis | 30 µrad |
| Frequency Response | 4 kHz |
| Operating Temperature | -20 °C to 80 °C |
| Maximum Axial Load | 200 g |
| Maximum Radial Load | 200 g |
| Moment of Inertia | 29.2 g·mm² |
| Max Current over velocity range | 300 mA |
| Rotor Runout | ≤ 50 µm |
| DIMENSIONS & WEIGHT | |
| Actuator Dimensions (no shaft) | 13 × 18.7 × 8.15 mm |
| Actuator Weight | 3.5 g / 4.0 g |
| Driver PCB Dimensions | 28 × 28 × 9.6 mm |
| Driver PCB Weight | 4.3 g |
| ORDERING INFORMATION | ||||
| Model | Enclosure | Encoder | Part Number | Kit Number* |
|---|---|---|---|---|
| ROMO-M | Metal | No | ROMO-M012-0370-0000 | ROMO-M012-0371-0000 |
| ROMO-P | Plastic | No | ROMO-P011-0370-0000 | ROMO-P011-0371-0000 |
ROMO-E
Rotary Piezo Motor with Encoder
Rotary Piezo Motor with Encoder
Hollow Shaft | Plastic & Metal Enclosures | With Encoder
Identical to ROMO base motor with factory-fitted magnetic encoder.
Encoder signal output enables closed-loop control via your
controller. Plastic (ROMO-E-P) or anodized aluminum (ROMO-E-M)
enclosure.
| MOTOR SPECIFICATIONS | |
| Power Supply Voltage | 7.5 V DC |
| Stall Torque | ≥ 4 mNm |
| Self-Braking Torque | ≥ 5 mNm |
| Actuator Response Time | < 30 µs |
| Max Speed | > 600 rpm |
| Minimum Angular Step | < 30 µrad |
| Encoder Resolution (after quadrature) | 1,024 ppr |
| Minimum Controlled Angular Step | 6.1 mrad |
| Uni-directional Repeatability | 6.1 mrad |
| Angular Backlash | 30 µrad |
| Angular Hysteresis | 30 µrad |
| Frequency Response | 4 kHz |
| Operating Temperature | -20 °C to 80 °C |
| Maximum Axial Load | 200 g |
| Maximum Radial Load | 200 g |
| Moment of Inertia | 29.2 g·mm² |
| Max Current over velocity range | 300 mA |
| Rotor Runout | ≤ 50 µm |
| DIMENSIONS & WEIGHT | |
| Actuator Dimensions (no shaft) | 13 × 18.7 × 9.15 mm |
| Actuator Weight | 4.2 g / 5.2 g |
| Driver PCB Dimensions | 28 × 28 × 9.6 mm |
| Driver PCB Weight | 4.3 g |
| ORDERING INFORMATION | ||||
| Model | Enclosure | Encoder | Part Number | Kit Number* |
|---|---|---|---|---|
| ROMO-E-M | Metal | Yes | ROMO-M012-1370-0000 | ROMO-M012-1371-0000 |
| ROMO-E-P | Plastic | Yes | ROMO-P011-1370-0000 | ROMO-P011-1371-0000 |
ROMO-E-CL
Rotary Piezo Motor System with Closed-Loop Software
Rotary Piezo Motor System with Closed-Loop Software
Hollow Shaft | Plastic & Metal Enclosures | With Encoder
Fully integrated closed-loop system. Combines the ROMO-E encoder motor with PMC’s dedicated closed-loop driver PCB and Python API software. Position and velocity commands via USB. Plastic or anodized aluminum enclosure.
| MOTOR SPECIFICATIONS | |
| Power Supply Voltage | 5.0 V DC |
| Stall Torque | ≥ 4 mNm |
| Self-Braking Torque | ≥ 5 mNm |
| Actuator Response Time | < 30 µs |
| Max Speed | > 600 rpm |
| Minimum Angular Step | < 30 µrad |
| Encoder Resolution (after quadrature) | 1,024 ppr |
| Minimum Controlled Angular Step | 6.1 mrad |
| Uni-directional Repeatability | 6.1 mrad |
| Angular Backlash | 30 µrad |
| Angular Hysteresis | 30 µrad |
| Frequency Response | 4 kHz |
| Operating Temperature | -20 °C to 80 °C |
| Maximum Axial Load | 200 g |
| Maximum Radial Load | 200 g |
| Moment of Inertia | 29.2 g·mm² |
| Max Current over velocity range | 300 mA |
| Rotor Runout | ≤ 50 µm |
| DIMENSIONS & WEIGHT | |
| Actuator Dimensions (no shaft) | 13 × 18.7 × 9.15 mm |
| Actuator Weight | 4.2 g / 5.2 g |
| Driver PCB Dimensions | 28 × 28 × 9.6 mm |
| Driver PCB Weight | 4.3 g |
| ORDERING INFORMATION | ||||
| Model | Enclosure | Encoder | Part Number | Kit Number* |
|---|---|---|---|---|
| ROMO-M | Metal | No | ROMO-M012-0370-0000 | ROMO-M012-0371-0000 |
| ROMO-P | Plastic | No | ROMO-P011-0370-0000 | ROMO-P011-0371-0000 |
MOTION CONTROL
Motion Control & Electronics
Three driver tiers, matched to how much control you need:
Open-loop
(RED driver)
(RED driver)
PWM, UART, or I²C control, no position feedback. Works with any ROMO-P/M or ROMO-E-P/M motor. Choose this if your system already has its own positioning logic, or you don’t need closed-loop feedback at all.
Closed-loop
(BLUE driver)
(BLUE driver)
Encoder feedback processed onboard, controlled via PMC’s Python API over USB. Works with ROMO-E-P/M motors only. Choose this if you want position/velocity commands in, and correct motion out, with no external controller.
I²C multi-axis
(either RED or BLUE)
(either RED or BLUE)
Daisy-chain up to six driver boards off one I²C adapter for synchronized multi-motor systems.
Technical
Downloads
Downloads
DOWNLOADS
INDUSTRIES
Industries &
Applications
Applications
Our innovative piezoelectric motors are engineered to meet the diverse demands of various high-tech industries, providing precise and efficient motion control solutions that drive progress and innovation.

Photonics & Optics
Laser alignment, fiber positioning, beam steering, micro-mirror control.

Microscopy and Life Sciences
Sample scanning, precision focus control, confocal imaging, live-cell microscopy.

Medical Devices & Diagnostics
Wearable devices, portable diagnostics, analytical instrumentation.

Semiconductor Manufacturing
Wafer inspection, lithography alignment, die-level positioning.

Scientific Research
Spectroscopy, AFM, advanced optical experiments, quantum systems.

Embedded and
Portable Instruments
Battery-operated systems requiring precision motion in minimal space.

Test & Measurement
Probe positioning, calibration systems, micro-alignment stages.